

NVIDIA has expanded its Cosmos platform for world models with new training tools, simulation checkpoints and a set of Cosmos Data Factory blueprints, in an announcement published on its official blog on October 22 during GTC Berlin. The update targets the slowest parts of building physical AI: preparing training data, adapting a model, testing its behaviour and getting it deployed.
Cosmos is NVIDIA’s open platform of world models — systems that learn how the physical world looks and behaves, so robots and self-driving vehicles can practise in simulation before acting in the real world. NVIDIA says the platform now ranks in the top five on six different open-model leaderboards, a company claim it uses to position Cosmos as the default open stack for physical AI development.
Cosmos Data Factory: Five Blueprints For Training Data
The data layer is Cosmos Data Factory, which brings together tools for labelling, curating, augmenting and evaluating training data at scale. Cosmos Curator, the GPU-accelerated engine for curating video datasets, has added support for multimodal, multisensory inputs and new processing blocks, reflecting the mix of camera, LiDAR and other sensor data that physical AI systems learn from.
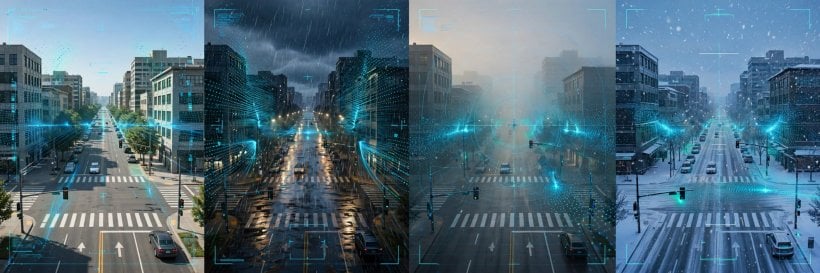
On top of Curator sit five cloud-native blueprints, available through GitHub, Microsoft Azure, Nebius and CoreWeave: autonomous vehicle dataset generation, which curates and labels driving data and adds synthetic examples of hard-to-capture scenarios; image attribute augmentation, which varies object appearance to improve image search; event video generation, which turns still images into synthetic videos of rare or unsafe events; defect image generation for printed circuit boards, metal and glass; and video data augmentation, which changes weather and lighting in existing footage while preserving the scene.
NVIDIA named early users for each pattern. Porsche is leading a shared autonomous-vehicle data flywheel across Volkswagen Group brands, using Cosmos Data Factory through Voxel51 on Microsoft Azure, with expected reductions of up to 90% in repeated physical test drives and up to 85% in development cycle times. ANYbotics generated more than 1,500 synthetic video clips to train industrial-inspection robots to recognise liquid spills, and Ultralytics retrained its YOLO model with real images plus synthetic defect examples, improving defect localisation and recall.
Cosmos Framework: Training Recipes Offered As Agent Skills
At GTC Berlin, NVIDIA also extended the Cosmos Framework’s training, optimisation and deployment tools and recipes as agent skills to more open models, alongside Cosmos 3 itself. Developers — and coding agents working for them — can now adapt open models such as GR00T, Alpamayo, Qwen and Pi0.5, plus other compatible Hugging Face models, through fine-tuning and reinforcement learning, then apply distillation and quantisation before deployment.
The company gave one worked example: robotics research lab MicroAGI post-trained Cosmos 3 on videos of human object manipulation for egocentric manipulation work, then distilled its 32-billion-parameter reasoner down to an 8-billion-parameter Nano model with, NVIDIA says, no loss in accuracy. Developers can also label data and post-train Cosmos 3 on Roboflow for their own environments, then deploy to Roboflow-hosted or on-premises NVIDIA GPUs.
Cosmos 3 Nano Variants And Faster NIM Inference
For testing, NVIDIA released new Cosmos 3 Nano model variants for simulation, letting developers evaluate autonomous policies in repeatable, hard-to-capture, multiview and multisensor scenarios. Accompanying code adapts the models to train and evaluate policies for autonomous vehicles and bimanual robots in interactive simulations before real-world testing.
Deployment runs through updated Cosmos 3 NIM microservices, which NVIDIA says deliver up to twice the inference speed with no quality loss in validated configurations, with continuous video analysis enabling sub-second alerts. The new Metropolis Blueprint for video search and summarisation, version 3.3, is built on those microservices and, NVIDIA says, lets teams monitor 40% more video streams on the same GPU. ADNOC already uses Fogsphere’s MistIQ platform, built with Cosmos and the Metropolis blueprint, to detect safety hazards in real time across 65 sites.
Why It Matters
Cosmos matters because the bottleneck in physical AI has shifted from model architecture to data and workflow. Robots and vehicles need enormous volumes of labelled, edge-case-rich training material that is expensive or dangerous to collect in the real world, and every team currently assembles that pipeline by hand. By packaging data generation, training recipes and deployment into one open platform — and exposing the recipes as skills that agents themselves can invoke — NVIDIA is trying to make Cosmos the standard workbench underneath other companies’ robots and vehicles, in the same way its earlier GTC Berlin releases, from the OpenShell reference architecture for safe agents to the Isaac robotics expansion, extend its reach from chips into the software layer where physical AI is actually built. The named users — Porsche across the Volkswagen Group, ANYbotics, ADNOC’s safety monitoring — are the evidence NVIDIA offers that the workbench is already in production use, complementing model releases such as Cosmos3-H-Dreams for robotic surgery.
Background
NVIDIA introduced Cosmos at CES in January 2025 as a family of open world foundation models for physical AI, and has expanded it steadily since, adding reasoning models, data tools and the Cosmos 3 generation. The platform sits at the centre of NVIDIA’s GTC Berlin push this week, which has also brought new Isaac robotics tools, the DSX POD modular AI factory and a wave of supply-chain capacity deals, as the company works to own not just the accelerators but the full development stack for robots, vehicles and industrial systems.
Source: NVIDIA Blog, AI Parabellum

0 Comments